SBIR Topic: SOCOM254-P006 — PEO SOF Warrior – Visual Augmentation Systems (VAS) Open Topic · Sponsor: USSOCOM · Phase I complete; Phase II awarded
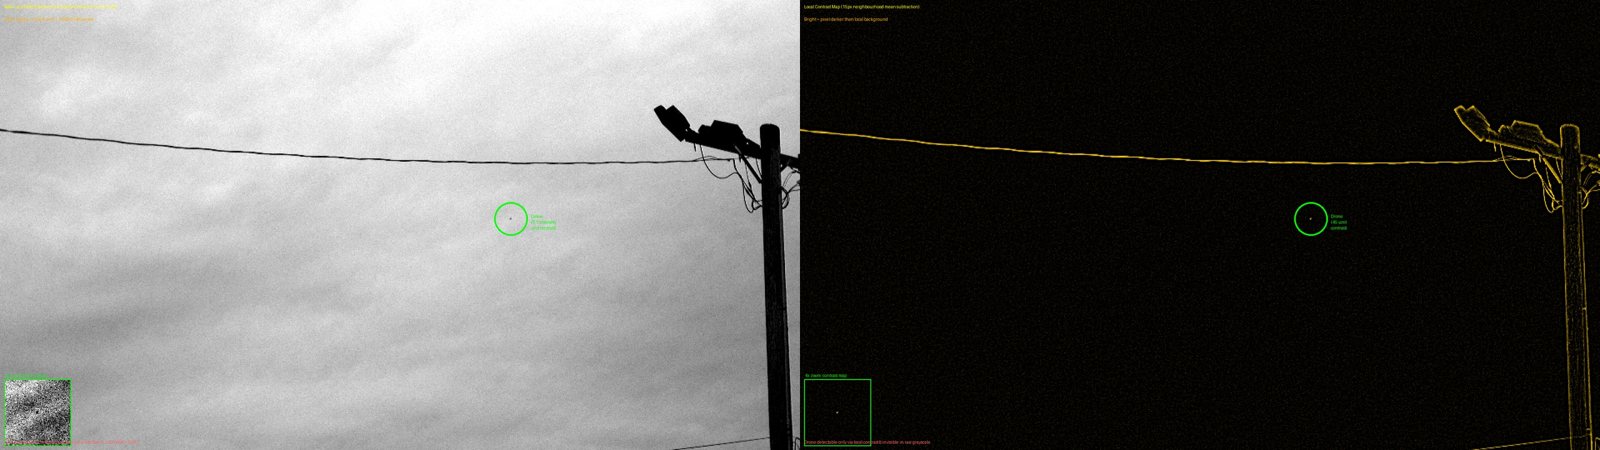
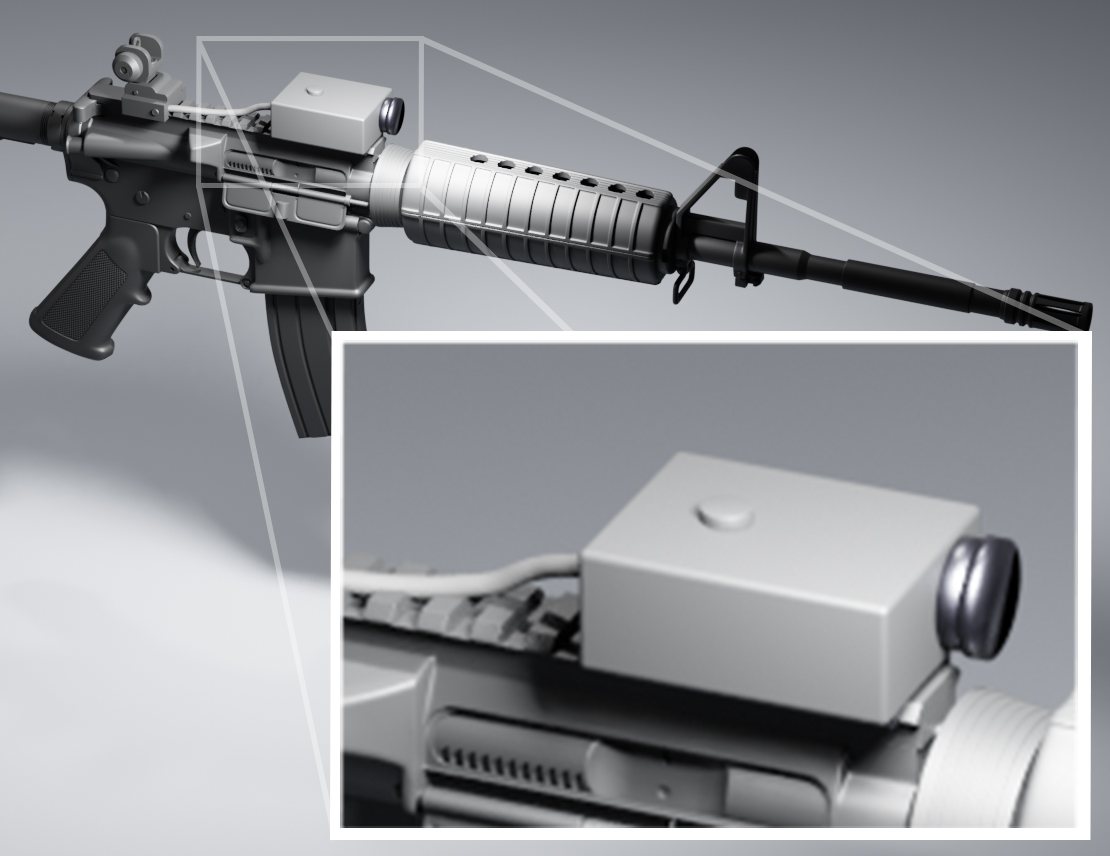
Small drones have become one of the most common threats to dismounted forces: cheap, fast, maneuverable, and hard to hit at the sub-200-meter ranges where an operator has to defeat them. Conventional weapon optics were not built for that problem. Frame-based sensors blur fast targets, add latency, wash out in sun and muzzle flash, and leave the operator estimating lead by eye. NeuroSight Scope addresses that gap with a passive, low-SWaP fire control aid built around an event-based camera.
Note: Some details have been altered, obscured, or sanitized to safeguard operational security and proprietary methods.
Why Event-Based
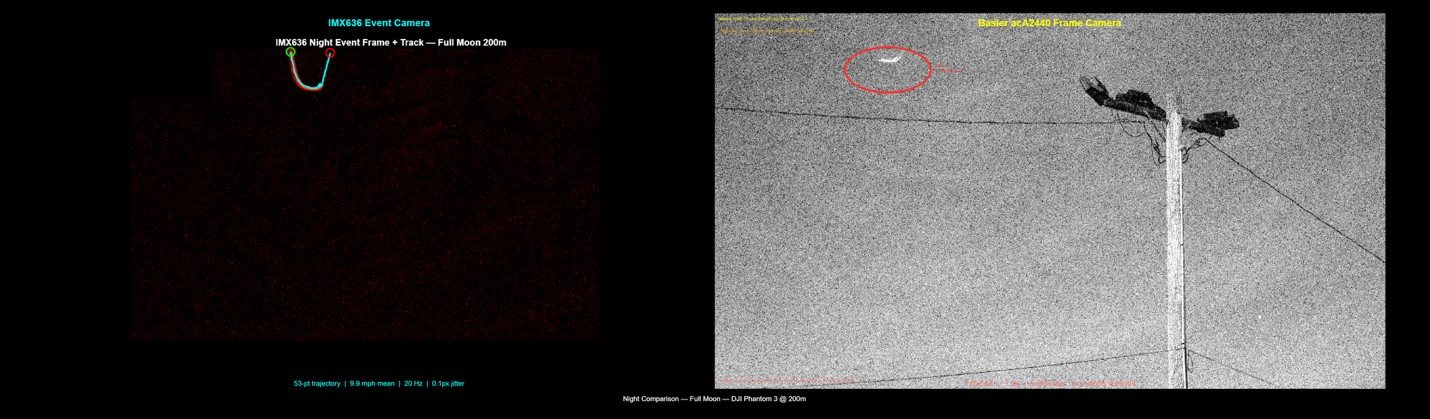
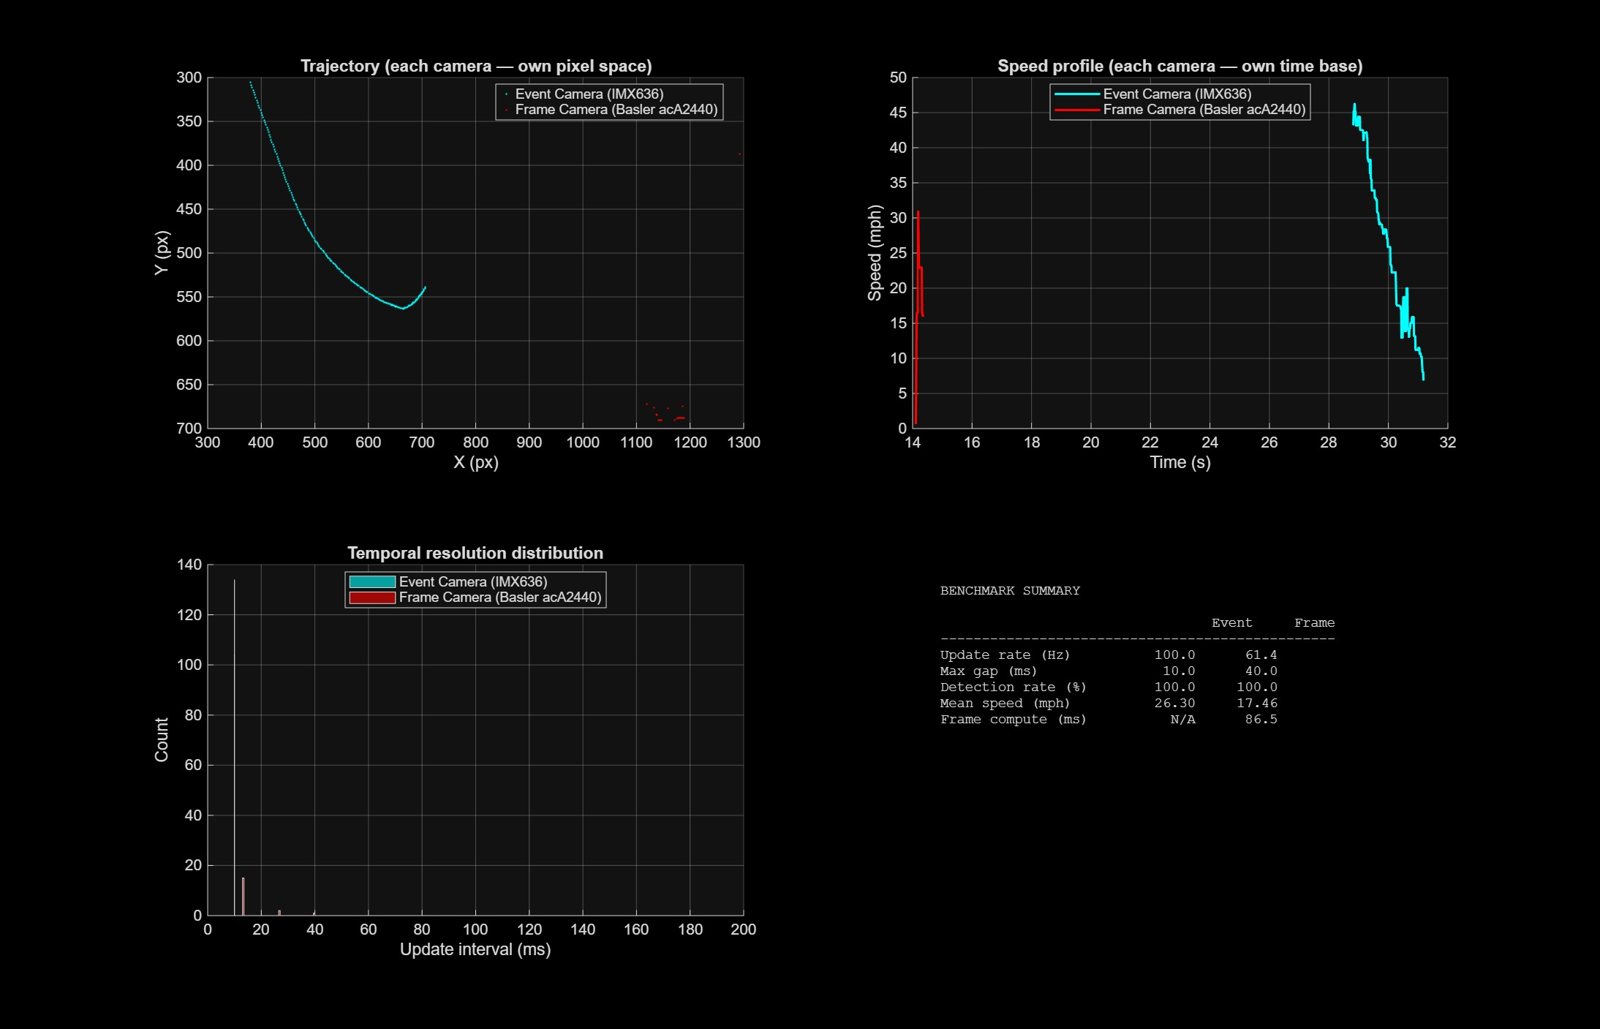
An event-based (neuromorphic) sensor doesn’t capture frames. Each pixel independently reports brightness changes with microsecond timing and more than 120 dB of dynamic range. The result is no motion blur, very low latency, and a sparse data stream that small embedded processors can handle on battery power.
Our Approach
With Alwyn Smith as Principal Investigator, our engineers led the technical architecture and integration of the weapon-mounted sensor and processing unit. Phase I built and validated the core of the fire control chain:
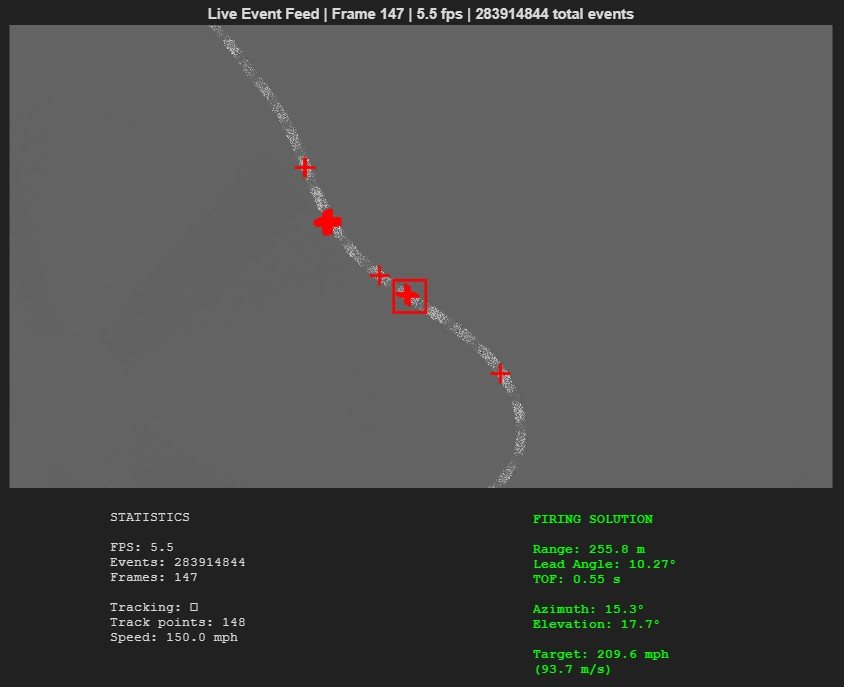
- Event-domain detection and multi-target tracking of small UAS
- Inertial-aided ego-motion estimation for steady pointing from a moving weapon
- A continuously computed, ballistically corrected aimpoint presented in the operator’s line of sight
- A low-SWaP compute design on an AMD Kria K26 system-on-module
The Phase I design closed at roughly 2.5 W, 196 g, and 153 cm³.
Outcome
Phase II matures the design into fieldable prototypes, including external cueing from networked sensors. The underlying event-based platform continues at Paladin as Balor.
Project Images