SBIR Topic: A244-P056 — Mobile Sustainment Tools Open Topic · Sponsor: U.S. Army · Phase I complete
Depot-level fabrication and repair capability usually sits far from where it is needed most. MANTIS is a mobile, collaborative robotic work cell that brings depot-grade precision to forward and expeditionary environments.
Note: Some details have been altered, obscured, or sanitized to safeguard operational security and proprietary methods.
Our Approach
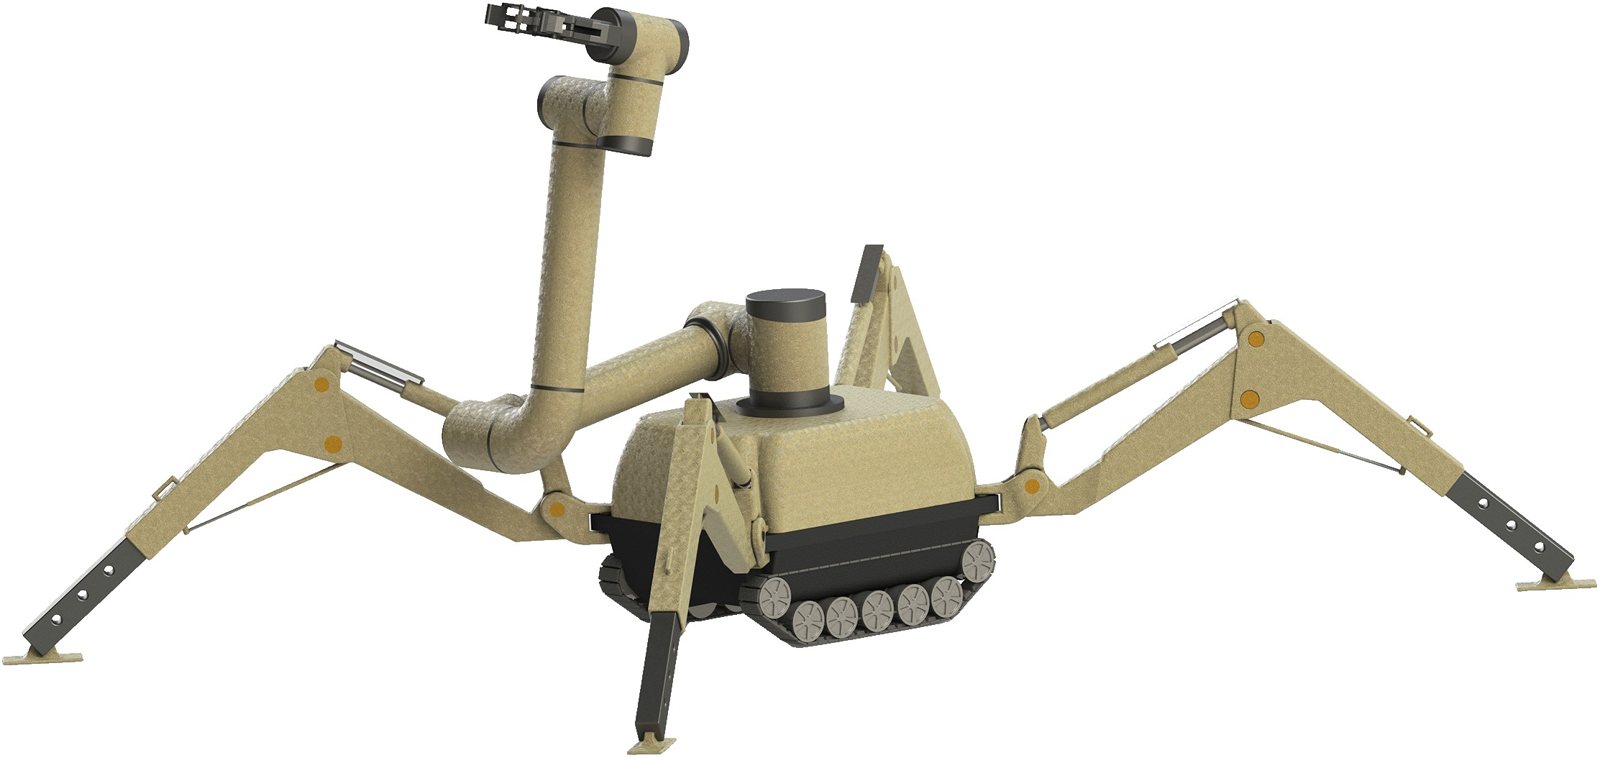
Under Alwyn Smith as Principal Investigator and Chief Engineer, our team led the mobile robotic architecture. MANTIS uses a tracked spider base with hydraulic stabilizing outriggers; a six-degree-of-freedom arm with an automatic tool changer and modular end-effectors; a 48 V hybrid power system for quiet battery operation and extended generator-supported missions; and human-supervised autonomy. One containerized, relocatable cell covers assembly, grinding, welding, painting, and material handling.
Dual-Use Applicability
The same approach extends to aerospace MRO, energy and mining, disaster relief, and construction.
Project Images