SBIR Topic: N241-027 — Precision Stabilization of Large, Wide Field of View Imaging Sensors · Sponsor: U.S. Navy · Phase I complete
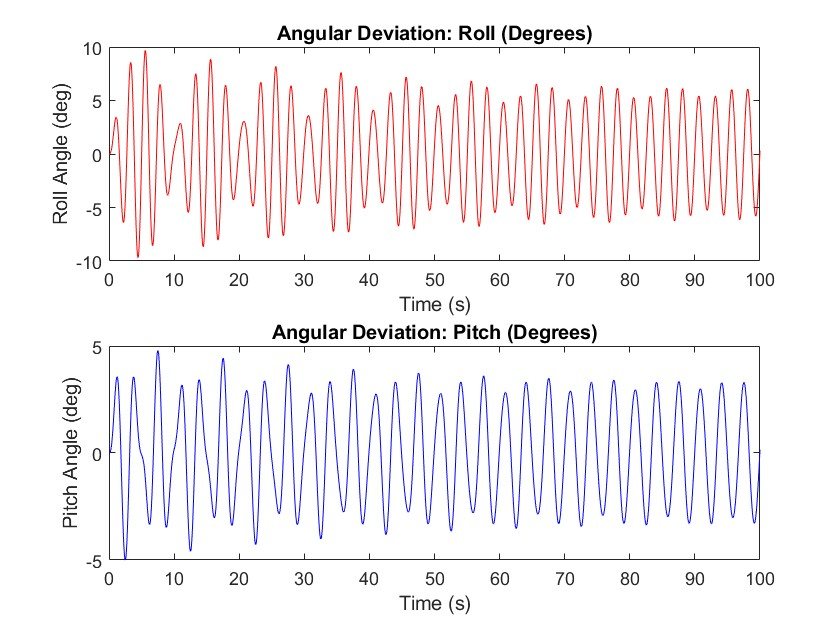
Sensors that perform well on a static bench often degrade sharply once mounted on a moving, vibrating ship. This effort addressed precision stabilization of large, fixed, wide-field-of-view shipboard imaging sensors.
Note: Some details have been altered, obscured, or sanitized to safeguard operational security and proprietary methods.
Our Approach
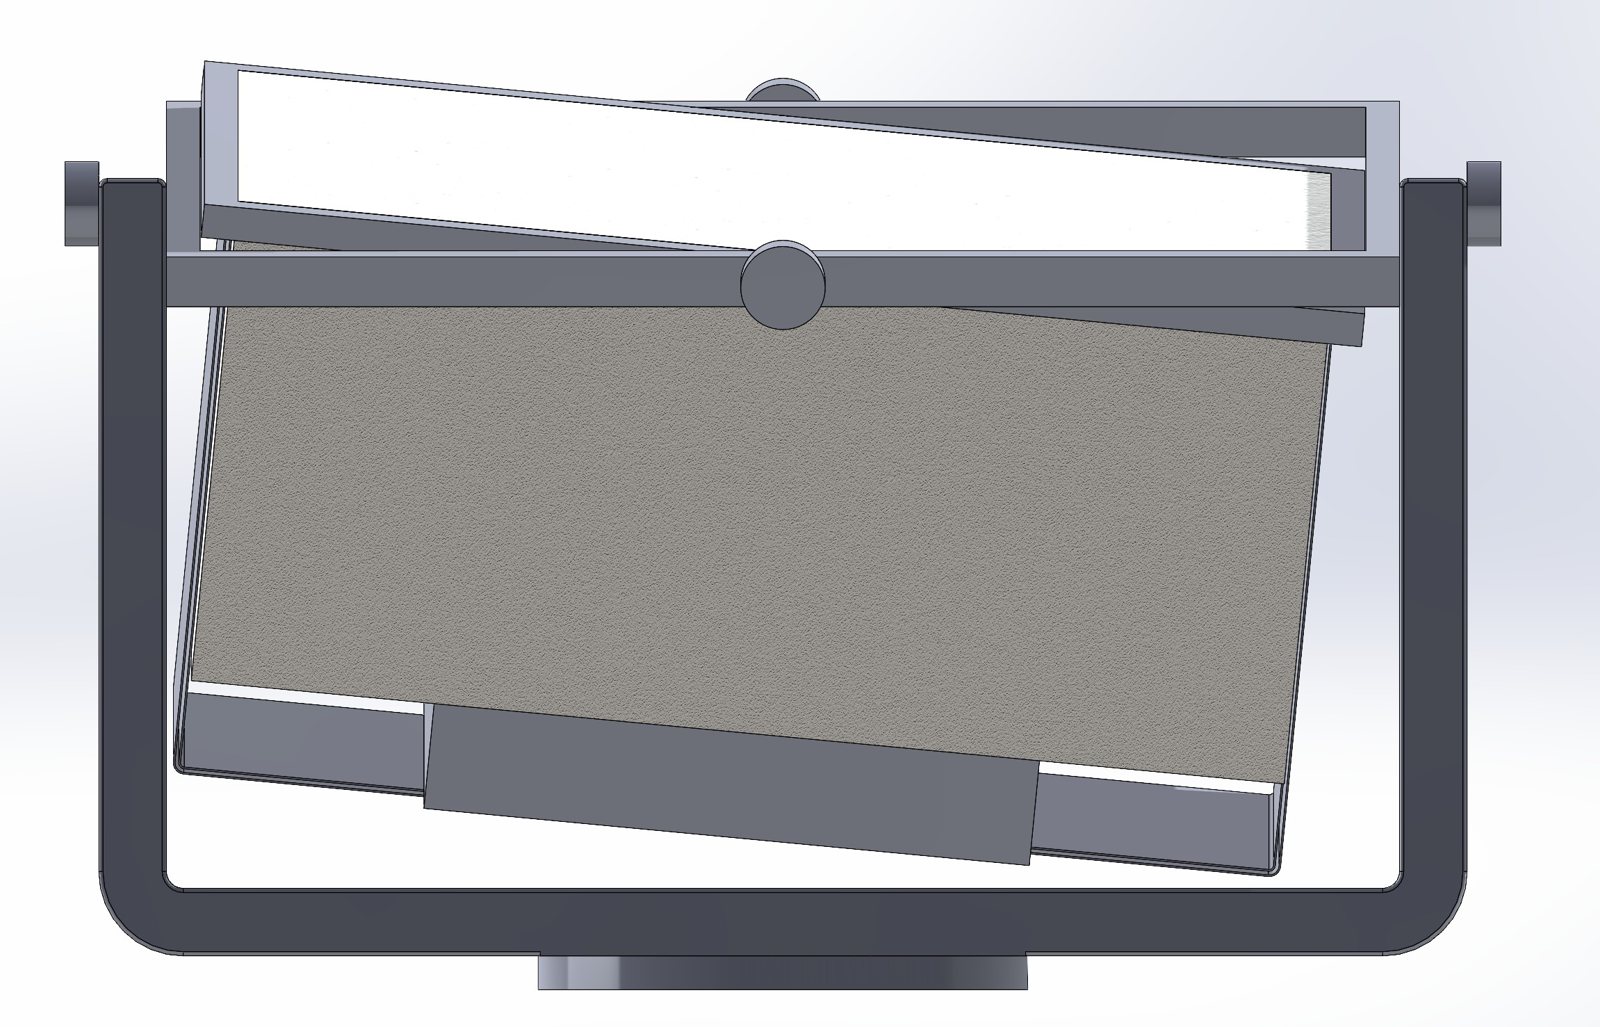
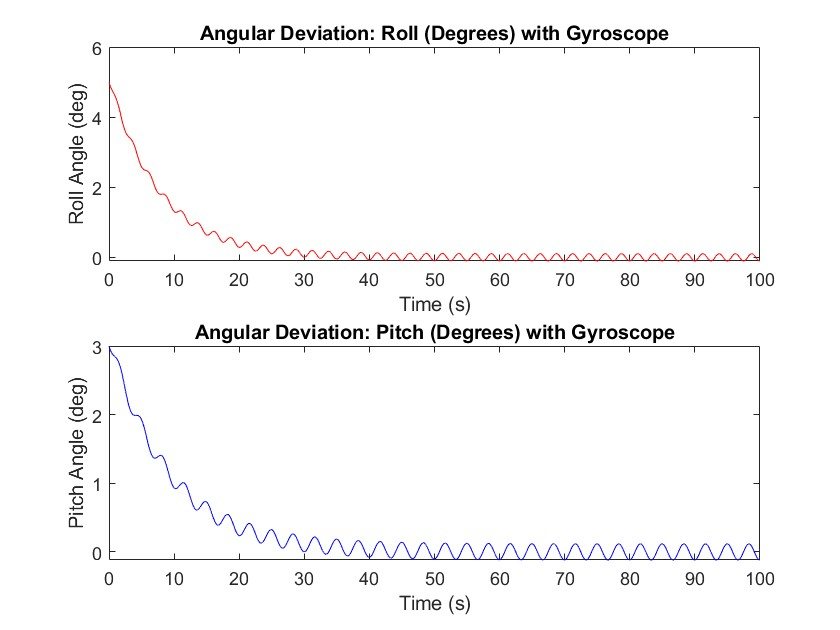
Under Alwyn Smith as Principal Investigator, our team directed the mechanical, electromechanical, and control-system design of a stabilized mount. The design combined a gyroscopic/flywheel stabilization approach with active damping, magnetorheological damping, and vibration isolation, working toward a ruggedized shipboard configuration.
Capabilities Demonstrated
The effort applied Paladin’s core competency in gyro-stabilized, gimbaled sensor platforms to wide-FOV imaging under motion. That work bears directly on stabilized EO/IR payloads, maritime sensing, and ruggedized optical systems.
Project Images